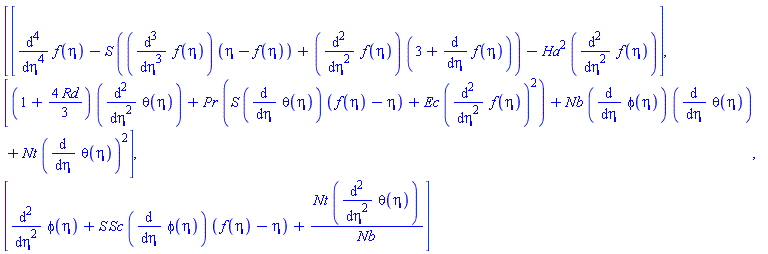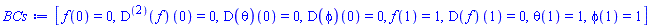MaplePrimes Posts

MaplePrimes Posts are for sharing your experiences, techniques and opinions about Maple, MapleSim and related products, as well as general interests in math and computing.

Latest Post
  • Latest Posts Feed
  • From time to time, people ask me about visualizing knots in Maple. There's no formal "Knot Theory" package in Maple per se, but it is certainly possible to generate many different knots using a couple of simple commands. The following shows various examples of knots visualized using the plots:-tubeplot and algcurves:-plot_knot commands.

    The unknot can be defined by the following parametric equations:


    x=sin(t)

    y=cos(t)

    z=0


    plots:-tubeplot([cos(t),sin(t),0,t=0..2*Pi],
       radius=0.2, axes=none, color="Blue", orientation=[60,60], scaling=constrained, style=surfacecontour);


    plots:-tubeplot([cos(t),sin(t),0,t=0..2*Pi],    radius=0.2,axes=none,color=


    The trefoil knot can be defined by the following parametric equations:


    x = sin(t) + 2*sin(2*t)

    y = cos(t) + 2*sin(2*t)

    z = sin(3*t)


    plots:-tubeplot([sin(t)+2*sin(2*t),cos(t)-2*cos(2*t),-sin(3*t), t= 0..2*Pi],
       radius=0.2, axes=none, color="Green", orientation=[90,0], style=surface);


    plots:-tubeplot([sin(t)+2*sin(2*t),cos(t)-2*cos(2*t),-sin(3*t),t= 0..2*Pi],    radius=0.2,axes=none,color=


    The figure-eight can be defined by the following parametric equations:


    x = (2 + cos(2*t)) * cos(3*t)

    y = (2 + cos(2*t)) * sin(3*t)

    z = sin(4*t)


    plots:-tubeplot([(2+cos(2*t))*cos(3*t),(2+cos(2*t))*sin(3*t),sin(4*t),t=0..2*Pi],
       numpoints=100, radius=0.1, axes=none, color="Red", orientation=[75,30,0], style=surface);


    plots:-tubeplot([(2+cos(2*t))*cos(3*t),(2+cos(2*t))*sin(3*t),sin(4*t),t=0..2*Pi],    numpoints=100,radius=0.1,axes=none,color=


    The Lissajous knot can be defined by the following parametric equations:


    x = cos(t*n[x]+phi[x])

    y = cos(t*n[y]+phi[y])

    z = cos(t n[z] + phi[z])

    Where n[x], n[y], and n[z] are integers and the phase shifts phi[x], phi[y], and phi[z] are any real numbers.
    The 8 21 knot ( n[x] = 3, n[y] = 4, and n[z] = 7) appears as follows:
     

    plots:-tubeplot([cos(3*t+Pi/2),cos(4*t+Pi/2),cos(7*t),t=0..2*Pi],
       radius=0.05, axes=none, color="Brown", orientation=[90,0,0], style=surface);


    plots:-tubeplot([cos(3*t+Pi/2),cos(4*t+Pi/2),cos(7*t),t=0..2*Pi],    radius=0.05,axes=none,color=


    A star knot can be defined by using the following polynomial:
     

    f = -x^5+y^2


    f := -x^5+y^2
    algcurves:-plot_knot(f,x,y,epsilon=0.7,
       radius=0.25, tubepoints=10, axes=none, color="Orange", orientation=[60,0], style=surfacecontour);


    By switching x and y, different visualizations can be generated:


    g=(y^3-x^7)*(y^2-x^5)+y^3


    g:=(y^3-x^7)*(y^2-x^5)+y^3;
    plots:-display(<
    algcurves:-plot_knot(g,y,x, epsilon=0.8, radius=0.1, axes=none, color="CornflowerBlue", orientation=[75,30,0])|
    algcurves:-plot_knot(g,x,y, epsilon=0.8, radius=0.1, axes=none, color="OrangeRed", orientation=[75,0,0])>);


    f = (y^3-x^7)*(y^2-x^5)


    f:=(y^3-x^7)*(y^2-x^5);
    algcurves:-plot_knot(f,x,y,
      epsilon=0.8, radius=0.1, axes=none, orientation=[35,0,0]);


    h=(y^3-x^7)*(y^3-x^7+100*x^13)*(y^3-x^7-100*x^13)


    h:=(y^3-x^7)*(y^3-x^7+100*x^13)*(y^3-x^7-100*x^13);

    algcurves:-plot_knot(h,x,y,
       epsilon=0.8, numpoints=400, radius=0.03, axes=none, color=["Blue","Red","Green"], orientation=[60,0,0]);


    Please feel free to add more of your favourite knot visualizations in the comments below!

    You can interact with the examples or download a copy of these examples from the MapleCloud here: https://maple.cloud/app/5654426890010624/Examples+of+Knots

    In this post an interesting geometric problem is solved: for an arbitrary convex polygon, find a straight line that divides both the area and the perimeter in half. The following results on this problem are well known:
    1. For any convex polygon there is such a straight line.
    2. For any convex polygon into which a circle can be inscribed, in particular for any triangle, the desired line must pass through the center of the inscribed circle.
    3. For a triangle, the number of solutions can be 1, 2, or 3.
    4. If the polygon has symmetry with respect to a point, then any straight line passing through this point is a solution.

    The procedure called  InHalf  (the code below) symbolically solves this problem. The formal parameter of the procedure is the list of coordinates of the vertices of a convex polygon (vertices must be passed opposite or clockwise). The procedure returns all solutions in the form of a list of pairs of points, lying on the perimeter of the polygon, that are the ends of segments that implement the desired dividing.


    > 

    restart;

    > 

    InHalf:=proc(V::listlist)
    local L, n, a, b, M, N, i, j, P, Q, L1, L2, Area, Area1, Area2, Perimeter, Perimeter1, Perimeter2, sol, m, k, Sol;
    uses LinearAlgebra, ListTools;
    L:=map(convert,[V[],V[1]],rational); n:=nops(L)-1;
    a:=<(V[2]-V[1])[1],(V[2]-V[1])[2],0>; b:=<(V[n]-V[1])[1],(V[n]-V[1])[2],0>;
    if is(CrossProduct(a,b)[3]<0) then L:=Reverse(L) fi;
    M:=[seq([L[i],L[i+1]], i=1..n)]:
    N:=0;
    for i from 1 to n-1 do
    for j from i+1 to n do
    P:=map(t->t*(1-s),M[i,1])+map(t->t*s,M[i,2]); Q:=map(s->s*(1-t),M[j,1])+map(s->s*t,M[j,2]);
    L1:=[P,L[i+1..j][],Q,P];
    L2:=[Q,L[j+1..-1][],L[1..i][],P,Q];
    Area:=L->(1/2)*add(L[k, 1]*L[k+1, 2]-L[k, 2]*L[k+1, 1], k = 1 .. nops(L)-1);
    Area1:=Area(L1);
    Area2:=Area(L2);
    Perimeter:=L->add(sqrt((L[k,1]-L[k+1,1])^2+(L[k,2]-L[k+1,2])^2), k=1..nops(L)-2);
    Perimeter1:=Perimeter(L1);
    Perimeter2:=Perimeter(L2);
    sol:=[solve({Area1=Area2,Perimeter1=Perimeter2,s>=0,s<1,t>=0,t<1}, {s,t}, explicit)] assuming real;
    if sol<>[] then m:=nops(sol);
    for k from 1 to m do
    N:=N+1; if nops(sol[k])=2 then Sol[N]:=simplify(eval([P,Q],sol[k])) else Sol[N]:=simplify(eval([P,Q],s=t)) fi;
    od; fi;
    od; od;
    Sol:=convert(Sol, list);
    `if`(indets(Sol)={},Sol,op([Sol,t>=0 and t<1]));
    end proc:  


    Examples of use

    > 

    # For the Pythagorean triangle with sides 3, 4, 5, we have a unique solution

    L:=[[4,3],[4,0],[0,0]]:
    P:=InHalf(L);
    plots:-display(plot([L[],L[1]], color=green, thickness=3), plot(P,  color=red), scaling=constrained);

    [[[8/5-(2/5)*6^(1/2), 6/5-(3/10)*6^(1/2)], [4, (1/2)*6^(1/2)]]]


    > 

    # For an isosceles right triangle, there are 3 solutions. We see that all the cuts pass through the center of the inscribed circle

    L:=[[0,0],[4,0],[4,4]]:
    InHalf(L);
    P:=InHalf(L);
    r:=(4+4-4*sqrt(2))/2: a:=4-r: b:=r:
    plots:-display(plot([L[],L[1]], color=green, thickness=3), plot(P,  color=red), plot([r*cos(t)+a,r*sin(t)+b, t=0..2*Pi], color=blue), scaling=constrained);

    [[[2*2^(1/2), 0], [2*2^(1/2), 2*2^(1/2)]], [[4, 0], [2, 2]], [[4, -2*2^(1/2)+4], [-2*2^(1/2)+4, -2*2^(1/2)+4]]]


    [[[2*2^(1/2), 0], [2*2^(1/2), 2*2^(1/2)]], [[4, 0], [2, 2]], [[4, -2*2^(1/2)+4], [-2*2^(1/2)+4, -2*2^(1/2)+4]]]


    > 

    # There are 3 solutions for the quadrilateral below

    L:=[[0,0],[4.5,0],[4,3],[0,2]]:
    P:=InHalf(L);
    plots:-display(plot([L[],L[1]], color=green, thickness=3), plot(P,  color=red), scaling=constrained);

    [[[(1/44844)*6^(1/2)*(17^(1/2)-13/2)*37^(3/4)*(2*17^(1/2)+13)^(1/2)*((1836*37^(1/2)-6956)*17^(1/2)+7995*37^(1/2)-56425)^(1/2)-(1/4)*17^(1/2)-(1/8)*37^(1/2)+23/8, 0], [(6^(1/2)*37^(1/4)*((1836*37^(1/2)-6956)*17^(1/2)+7995*37^(1/2)-56425)^(1/2)*(2*17^(1/2)+13)^(1/2)+(-156*37^(1/2)+7770)*17^(1/2)-711*37^(1/2)+50505)/(1776*17^(1/2)+11544), (-6^(1/2)*37^(1/4)*((1836*37^(1/2)-6956)*17^(1/2)+7995*37^(1/2)-56425)^(1/2)*(2*17^(1/2)+13)^(1/2)+(156*37^(1/2)+222)*17^(1/2)+711*37^(1/2)+1443)/(296*17^(1/2)+1924)]], [[(1/90576)*17^(3/4)*(37^(1/2)+37)^(1/2)*(37^(1/2)-37)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)+(5/4)*17^(1/2)+(1/8)*37^(1/2)-27/8, 0], [(17^(1/4)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)*(37^(1/2)+37)^(1/2)+(37*17^(1/2)-51)*37^(1/2)+703*17^(1/2)-1887)/(17*37^(1/2)+629), (17^(1/4)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)*(37^(1/2)+37)^(1/2)+(37*17^(1/2)+85)*37^(1/2)+703*17^(1/2)+3145)/(68*37^(1/2)+2516)]], [[-(1/90576)*17^(3/4)*(37^(1/2)+37)^(1/2)*(37^(1/2)-37)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)+(5/4)*17^(1/2)+(1/8)*37^(1/2)-27/8, 0], [(-17^(1/4)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)*(37^(1/2)+37)^(1/2)+(37*17^(1/2)-51)*37^(1/2)+703*17^(1/2)-1887)/(17*37^(1/2)+629), (-17^(1/4)*((1461*37^(1/2)+29415)*17^(1/2)-986*37^(1/2)-149702)^(1/2)*(37^(1/2)+37)^(1/2)+(37*17^(1/2)+85)*37^(1/2)+703*17^(1/2)+3145)/(68*37^(1/2)+2516)]]]


    > 

    # There are infinitely many solutions for a polygon with a center of symmetry. Any cut through the center solves the problem. The picture shows 2 solutions.

    L:=[[1,0],[1+2*sqrt(3),2],[2*sqrt(3),sqrt(3)+2],[0,sqrt(3)]]:
    P:=InHalf(L);
    plots:-display(plot([L[],L[1]], color=green, thickness=3), plot(eval(P[1],t=1/3),  color=red), scaling=constrained);

    [[[2*3^(1/2)*t+1, 2*t], [-2*3^(1/2)*(t-1), 3^(1/2)-2*t+2]], [[2*3^(1/2)-t+1, 3^(1/2)*t+2], [t, -3^(1/2)*(t-1)]]], 0 <= t and t < 1


    > 


    Download In_Half.mw

    We have just released an update to Maple, Maple 2018.2. This release includes improvements in a variety of areas, including code edit regions, Workbooks, and Physics, as well as support for macOS 10.14.

    This update is available through Tools>Check for Updates in Maple, and is also available from our website on the Maple 2018.2 download page, where you can also find more details.

    For MapleSim users, the update includes optimizations for handling large models, improvements to model import and export, updates to the hydraulics and pneumatics libraries, and more. For more details and download instructions, visit the MapleSim 2018.2 download page.

    The procedure presented here does independence tests of a contingency table by four methods:

    1. Pearson's chi-squared (equivalent to Statistics:-ChiSquareIndependenceTest),
    2. Yates's continuity correction to Pearson's,
    3. G-chi-squared,
    4. Fisher's exact.

    (All of these have Wikipedia pages. Links are given in the code below.) All computations are done in exact arithmetic. The coup de grace is Fisher's. The first three tests are relatively easy computations and give approximations to the p-value (the probability that the categories are independent), but Fisher's exact test, as its name says, computes it exactly. This requires the generation of all matrices of nonnegative integers that have the same row and column sums as the input matrix, and for each of these matrices computing the product of the factorials of its entries. So, there are relatively few implementations of it, and perhaps none that do it exactly. (Could some with access check Mathematica please?)

    Our own Joe Riel's amazing and fast Iterator package makes this computation considerably easier and faster than it otherwise would've been, and I also found inspiration in his example of recursively counting contingency tables found at ?Iterator,BoundedComposition. 

    ContingencyTableTests:= proc(
       O::Matrix(nonnegint), #contingency table of observed counts 
       {method::identical(Pearson, Yates, G, Fisher):= 'Pearson'}
    )
    description 
       "Returns p-value for Pearson's (w/ or w/o Yates's continuity correction)" 
       " or G chi-squared or Fisher's exact test."
       " All computations are done in exact arithmetic."
    ;
    option
       author= "Carl Love <carl.j.love@gmail.com>, 27-Oct-2018",
       references= (                                                           #Ref #s:
          "https://en.wikipedia.org/wiki/Pearson%27s_chi-squared_test",         #*1
          "https://en.wikipedia.org/wiki/Yates%27s_correction_for_continuity",  #*2
          "https://en.wikipedia.org/wiki/G-test",                               #*3
          "https://en.wikipedia.org/wiki/Fisher%27s_exact_test",                #*4
          "Eric W Weisstein \"Fisher's Exact Test\" _MathWorld_--A Wolfram web resource:"
          " http://mathworld.wolfram.com/FishersExactTest.html"                 #*5
       )
    ;
    uses AT= ArrayTools, St= Statistics, It= Iterator;
    local
       #column & row sums: 
       C:= AT:-AddAlongDimension(O,1), R:= AT:-AddAlongDimension(O,2),
       r:= numelems(R), c:= numelems(C), #counts of rows & columns
       n:= add(R), #number of observations
       #matrix of expected values under null hypothesis (independence):
       #(A 0 entry would mean a 0 row or column in the original, which is not allowed.)
       E:= Matrix((r,c), (i,j)-> R[i]*C[j], datatype= 'positive') / n,
       #Pearson's, Yates's, and G all use a chi-sq statistic, each computed by 
       #slightly different formulae.
       Chi2:= add@~table([
           'Pearson'= (O-> (O-E)^~2 /~ E),                     #see *1
           'Yates'= (O-> (abs~(O - E) -~ 1/2)^~2 /~ E),        #see *2
           'G'= (O-> 2*O*~map(x-> `if`(x=0, 0, ln(x)), O/~E))  #see *3
       ]), 
       row, #alternative rows generated for Fisher's
       Cutoff:= mul(O!~), #cut-off value for less likely matrices
       #Generate recursively all contingency tables whose row and column sums match O.
       #Compute their probabilities under independence. Sum probabilities of all those
       #at most as probable as O. (see *5, *4)
       #Parameters: 
       #   C = column sums remaining to be filled; 
       #   F = product of factorials of entries of contingency table being built;
       #   i = row to be chosen this iteration
       AllCTs:= (C, F, i)->
          if i = r then #Recursion ends; last row is C, the unused portion of column sums. 
             (P-> `if`(P >= Cutoff, 1/P, 0))(F*mul(C!~))
          else
             add(
                thisproc(C - row[], F*mul(row[]!~), i+1), 
                row= It:-BoundedComposition(C, R[i])
             )
          fi      
    ;
       userinfo(1, ContingencyTableTests, "Table of expected values:", print(E));
       if method = 'Fisher' then AllCTs(C, 1, 1)*mul(R!~)*mul(C!~)/n!
       else 1 - St:-CDF(ChiSquare((r-1)*(c-1)), Chi2[method](O)) 
       fi   
    end proc:
    

    The worksheet below contains the code above and one problem solved by the 4 methods


    > 


    > 

    DrugTrial:= <
       20, 11, 19;
       4,  4,  17
    >:

    > 

    infolevel[ContingencyTableTests]:= 1:

    > 

    ContingencyTableTests(DrugTrial, method= Pearson):  % = evalf(%);

    ContingencyTableTests: Table of expected values:

    Matrix(2, 3, {(1, 1) = 16, (1, 2) = 10, (1, 3) = 24, (2, 1) = 8, (2, 2) = 5, (2, 3) = 12})

    exp(-257/80) = 0.4025584775e-1

    > 

    #Compare with:
    Statistics:-ChiSquareIndependenceTest(DrugTrial);

    hypothesis = false, criticalvalue = HFloat(5.991464547107979), distribution = ChiSquare(2), pvalue = HFloat(0.04025584774823787), statistic = 6.425000000

    > 

    infolevel[ContingencyTableTests]:= 0:
    ContingencyTableTests(DrugTrial, method= Yates):  % = evalf(%);

    exp(-1569/640) = 0.8615885805e-1

    > 

    ContingencyTableTests(DrugTrial, method= G):  % = evalf(%);

    exp(-20*ln(5/4)+4*ln(2)-11*ln(11/10)-4*ln(4/5)-19*ln(19/24)-17*ln(17/12)) = 0.3584139703e-1

    > 

    CodeTools:-Usage(ContingencyTableTests(DrugTrial, method= Fisher)):  % = evalf(%);

    memory used=0.82MiB, alloc change=0 bytes, cpu time=0ns, real time=5.00ms, gc time=0ns

    747139720973921/15707451356376611 = 0.4756594205e-1

    > 


    Download FishersExact.mw

    Problem:

    Suppose you have a bunch of 2D data points which:

    1. May include points with the same x-value but different y-values; and
    2. May be unevenly-spaced with respect to the x-values.

    How do you clean up the data so that, for instance, you are free to construct a connected data plot, or perform a Discrete Fourier Transform? Please note that Curve Fitting and the Lomb–Scargle Method, respectively, are more effective techniques for these particular applications. Let's start with a simple example for illustration. Consider this Matrix:

    A := < 2, 5; 5, 8; 2, 1; 7, 8; 10, 10; 5, 7 >;

    Consolidate:

    First, sort the rows of the Matrix by the first column, and extract the sorted columns separately:

    P := sort( A[..,1], output=permutation ); # permutation to sort rows by the values in the first column
    U := A[P,1]; # sorted column 1
    V := A[P,2]; # sorted column 2

    We can regard the sorted bunches of distinct values in U as a step in a stair case, and the goal is replace each step with the average of the y-values in V located on each step.

    Second, determine the indices for the first occurrences of values in U, by selecting the indices which give a jump in x-value:

    m := numelems( U );
    K := [ 1, op( select( i -> ( U[i] > U[i-1] ), [ seq( j, j=2..m ) ] ) ), m+1 ];
    n := numelems( K );

    The element m+1 is appended for later convenience. Here, we can quickly define the first column of the consolidated Matrix:

    X1 := U[K[1..-2]];

    Finally, to define the second column of the consolidated Matrix, we take the average of the values in each step, using the indices in K to tell us the ranges of values to consider:

    Y1 := Vector[column]( n-1, i -> add( V[ K[i]..K[i+1]-1 ] ) / ( K[i+1] - K[i] ) );

    Thus, the consolidated Matrix is given by:

    B := < X1 | Y1 >;

    Spread Evenly:

    To spread-out the x-values, we can use a sequence with fixed step size:

    X2 := evalf( Vector[column]( [ seq( X1[1]..X1[-1], (X1[-1]-X1[1])/(m-1) ) ] ) );

    For the y-values, we will interpolate:

    Y2 := CurveFitting:-ArrayInterpolation( X1, Y1, X2, method=linear );

    This gives us a new Matrix, which has both evenly-spaced x-values and consolidated y-values:

    C := < X2 | Y2 >;

    Plot:

    plots:-display( Array( [
            plots:-pointplot( A, view=[0..10,0..10], color=green, symbol=solidcircle, symbolsize=15, title="Original Data", font=[Verdana,15] ),
            plots:-pointplot( B, view=[0..10,0..10], color=red, symbol=solidcircle, symbolsize=15, title="Consolidated Data", font=[Verdana,15] ),
            plots:-pointplot( C, view=[0..10,0..10], color=blue, symbol=solidcircle, symbolsize=15, title="Spread-Out Data", font=[Verdana,15] )
    ] ) );

    Sample Data with Noise:

    For another example, let’s take data points from a logistic curve, and add some noise:

    # Noise generators
    f := 0.5 * rand( -1..1 ):
    g := ( 100 - rand( -15..15 ) ) / 100:
    
    # Actual x-values
    X := [ seq( i/2, i=1..20 ) ];
    
    # Actual y-values
    Y := evalf( map( x -> 4 / ( 1 + 3 * exp(-x) ), X ) );
    
    # Matrix of points with noise
    A := Matrix( zip( (x,y) -> [x,y], map( x -> x + f(), X ), map( y -> g() * y, Y ) ) );

    Using the method outlined above, and the general procedures defined below, define:

    B := ConsolidatedMatrix( A );
    C := EquallySpaced( B, 21, method=linear );

    Visually:

    plots:-display( Array( [
        plots:-pointplot( A, view=[0..10,0..5], symbol=solidcircle, symbolsize=15, color=green, title="Original Data", font=[Verdana,15] ),
        plots:-pointplot( B, view=[0..10,0..5], symbol=solidcircle, symbolsize=15, color=red, title="Consolidated Data", font=[Verdana,15]  ),
        plots:-pointplot( C, view=[0..10,0..5], symbol=solidcircle, symbolsize=15, color=blue, title="Spread-Out Data", font=[Verdana,15] )
    ] ) );


    Generalization:

    Below are more generalized custom procedures, which are used in the above example. These also account for special cases.

    # Takes a matrix with two columns, and returns a new matrix where the new x-values are unique and sorted,
    # and each new y-value is the average of the old y-values corresponding to the x-value.
    ConsolidatedMatrix := proc( A :: 'Matrix'(..,2), $ )
    
            local i, j, K, m, n, P, r, U, V, X, Y:
      
            # The number of rows in the original matrix.
            r := LinearAlgebra:-RowDimension( A ):
    
            # Return the original matrix should it only have one row.
            if r = 1 then
                   return A:
            end if:
    
            # Permutation to sort first column of A.
            P := sort( A[..,1], ':-output'=permutation ):       
    
            # Sorted first column of A.
            U := A[P,1]:
    
            # Corresponding new second column of A.
            V := A[P,2]:
    
            # Return the sorted matrix should all the x-values be distinct.
            if numelems( convert( U, ':-set' ) ) = r then
                   return < U | V >:
            end if:
    
            # Indices of first occurrences for values in U. The element m+1 is appended for convenience.
            m := numelems( U ):
            K := [ 1, op( select( i -> ( U[i] > U[i-1] ), [ seq( j, j=2..m ) ] ) ), m+1 ]:
            n := numelems( K ):
    
            # Consolidated first column.
            X := U[K[1..-2]]:
    
            # Determine the consolidated second column, using the average y-value.
            Y := Vector[':-column']( n-1, i -> add( V[ K[i]..K[i+1]-1 ] ) / ( K[i+1] - K[i] ) ):
    
            return < X | Y >:
    
    end proc:
    
    # Procedure which takes a matrix with two columns, and returns a new matrix of specified number of rows
    # with equally-spaced x-values, and interpolated y-values.
    # It accepts options that can be passed to ArrayInterpolation().
    EquallySpaced := proc( M :: 'Matrix'(..,2), m :: posint )
    
            local A, i, r, U, V, X, Y:
    
            # Consolidated matrix, the corresponding number of rows, and the columns.
            A := ConsolidatedMatrix( M ):
            r := LinearAlgebra:-RowDimension( A ):
            U, V := evalf( A[..,1] ), evalf( A[..,2] ):
    
            # If the consolidated matrix has only one row, return it.
            if r = 1 then
                   return A:
            end if:
    
            # If m = 1, i.e. only one equally-spaced point is requested, then return a matrix of the averages.
            if m = 1 then
                   return 1/r * Matrix( [ [ add( U ), add( V ) ] ] ):
            end if:
    
            # Equally-spaced x-values.
            X := Vector[':-column']( [ seq( U[1]..U[-1], (U[-1]-U[1])/(m-1), i=1..m ) ] ):
    
            # Interpolated y-values.
            Y := CurveFitting:-ArrayInterpolation( U, V, X, _rest ):    
    
            return < X | Y >:
    
    end proc:

    Worth Checking Out:


    The attached worksheet shows how to evaluate and graphically analyze an autonomous first-order nonlinear recurrence with two dependent variables and multiple symbolic parameters. 

    This worksheet shows how a small module that simply encapsulates the given information of a problem combined with some use statements can greatly facilitate the organization of one's work, can encapsulate the setting of parameter values, and can allow one to work with symbolic parameters.

    Edit: In the first version of this Post, I forgot to include the qualifier "autonomous".  The system being autonomous substantially simplifies its treatment.
     

    Autonomous first-order nonlinear recurrences with parameters and multiple dependent variables

    Author: Carl Love <carl.j.love@gmail.com> 20-Oct-2018


    The techniques used in this worksheet can be applied to most autonomous first-order nonlinear recurrences with multiple dependent variables and parameters.


    This worksheet shows how a small module that simply encapsulates the given information of a problem combined with some use statements

    • 

    can greatly facilitate the organization of one's work,

    • 

    can encapsulate the setting of parameter values,

    • 

    can allow one to work with symbolic parameters.


    A Problem from MaplePrimes: A discrete Lottka-Volterra population model is applied to an isolated island with a population of predators (foxes), R, and prey (rabbits), K. [Note that R is the foxes, not the rabbits! Perhaps this problem statement originated in another language.] The change over one time period is given by

    K[n+1]:= K[n]*(-b*R[n]+a+1);  R[n+1]:= R[n]*(b*e*K[n]-c+1),

    where a, b, c, e are parameters of the model. In this problem we will use a= 0.15, b= 0.01, c= 0.02, e= 0.01, when numeric values are needed.


    a) Show that there exists an equilibrium (values of K[n] and R[n] such that K[n+1] = K[n] and R[n+1] = R[n]).


    b) Write Maple code that solves the recurrence numerically. Assume that if any population is less than 0.5 then it has gone extinct and set the value to 0. Check that your program is idempotent at the equilibrium.


    > 

    restart:

    We begin by collecting all the given information (except for specific numeric values) into a module. The ModuleApply lets the user set the numeric values later.


    For all two-element vectors used in this worksheet, K is the first value and R is the second value.

    > 

    KandR:= module()
    local
       a, b, c, e, #parameters

       #procedure that lets user set parameter values:
       ModuleApply:= proc({
           a::algebraic:= KandR:-a, b::algebraic:= KandR:-b,
           c::algebraic:= KandR:-c, e::algebraic:= KandR:-e
       })
       local k;
          for k to _noptions do thismodule[lhs(_options[k])]:= rhs(_options[k]) od;
          return
       end proc,

       Extinct:= (x::realcons)-> `if`(x < 0.5, 0, x) #force small, insignificant values to 0
    ;
    export
       #Procedure that does one symbolic iteration
       #(Note that this procedure uses Vector input and output.)
       iter_symb:= KR-> KR *~ <-b*KR[2]+a+1, b*e*KR[1]-c+1>, 

       #Such simple treatment as above is only possible for autonomous
       #recurrences.

      
       iter_num:= Extinct~@iter_symb #one numeric iteration
    ;
    end module:

    > 

    #The following expression is the discrete equivalent of the derivative (or gradient).
    #It represents the change over one time period.
    P:= <K,R>:  
    OneStep:= KandR:-iter_symb(P) - P

    Vector(2, {(1) = K*(-R*b+a+1)-K, (2) = R*(K*b*e-c+1)-R})

    > 

    #An equilibrium occurs when the gradient is 0.
    Eq:= <K__e, R__e>:
    Eqs:= solve({seq(eval(OneStep=~ 0, [seq(P=~ Eq)]))}, [seq(Eq)]);

    [[K__e = 0, R__e = 0], [K__e = c/(b*e), R__e = a/b]]

    > 

    #We're only interested here in nonzero solutions.
    EqSol:= remove(S-> 0 in rhs~(S), Eqs)[];

    [K__e = c/(b*e), R__e = a/b]

    > 

    #Set parameters:
    KandR(a= 0.15, b= 0.01, c= 0.02, e= 0.01);

    > 

    #Show idempotency at equilibrium:
    use KandR in Eq0:= eval(Eq, EqSol); print(Eq0 = iter_num(Eq0)) end use:

    (Vector(2, {(1) = 200.0000000, (2) = 15.00000000})) = (Vector(2, {(1) = 200.0000000, (2) = 15.00000000}))

    > 

    #procedure that fills a Matrix with computed values of a 1st-order recurrence.
    #(A more-efficient method than this can be used for linear recurrences.)
    #This procedure has no dependence on the module.
    Iterate:= proc(n::nonnegint, iter, init::Vector[column])
    local M:= Matrix((n+1, numelems(init)), init^+, datatype= hfloat), i;
       for i to n do M[i+1,..]:= iter(M[i,..]) od;
       M
    end proc:

    We want to see what happens if the initial conditions deviate slightly from the equilibrium. It turns out that any deviation (as long as the
    initial values are still nonnegative!) will cause the same effect. I simply chose the deviation <7,2> because it was the smallest for which

    the plot clearly showed what happens using the scale that I wanted to show the plot at. By using a finer scale, it is possible to see the

    "outward spiral" efffect from even the tiniest deviation.

    > 

    dev:= <7,2>:
    use KandR in KR:= Iterate(1000, iter_num, Eq0 + dev) end use:

    > 

    plot(
       [
           KR, #trajectory of population
           KR[[1,1],..], #1st point
           KR[-[1,1],..], #last point,
           <Eq0|Eq0>^+, #equilibrium
           #every 100th point (helps show time scale):
           KR[100*[$1..iquo(numelems(KR[..,1]), 100)-1], ..]
       ],
       #This group of options are all lists, each element of which corresponds
       #to one of the above components of the plot:
       style= [line, point$4],
       symbol= [solidcircle$4, soliddiamond],
       symbolsize= [18$4, 12],
       color= [black, green, red, brown, blue],
       thickness= [0$5],
       legend= [`pop.`, init, final, equilibrium, `100 periods`],

       #This group of options are lists, each element of which corresponds to one
       #coordinate axis (horizontal, then vertical).
       view= [0..max(KR[..,1]), 0..max(KR(..,2))],
       labels= [rabbits, foxes],
       labeldirections= [horizontal,vertical],
       size= [700,700], #measured in pixels

       #options applied to whole plot:
       labelfont= [TIMES, BOLDITALIC, 14],
       title= "Population of foxes and rabbits over time" "\n", titlefont= [TIMES,16],
       caption=
          "\n" "Choosing an initial point near the equilibrium causes"
          "\n" "outward spiraling divergence." "\n",
       gridlines= false
    );
     

    A fieldplot helps show what happens for any starting values. An arrow is drawn from each of a 2-D grid of point. The magnitude and direction of the arrow show the gradient (as a vector) in this case.

    > 

    plots:-fieldplot(
       rtable_eval(OneStep),
       K= 0..max(KR[..,1]),  R= 0..max(KR[..,2]), grid= [16,16],

       #arrow-specific options:
       anchor= tail, fieldstrength= log, arrows= slim, color= "DarkGreen",

       #other options (same as any 2D plot):
       labels= [rabbits, foxes], labeldirections= [horizontal,vertical],
       labelfont= [TIMES, BOLDITALIC, 14],
       title= "One-step population changes from any point" "\n", titlefont= [TIMES,16],
       caption= "\n" "All trajectories spiral outward from the equilibrium." "\n",
       size= [700,700],
       gridlines= false
    );

    The above plot is computed only from the symbolic discrete gradient expression OneStep; it does not use the computed population values from the first plot. It only uses the maxima of those computed values to determine the length of the axes.


    Conclusion: While this is interesting stuff mathematically, and makes for great plots, divergence from the equilibrium doesn't seem realistic to me.

    > 


    Download FoxesAndRabbits.mw

    With this application, you visualize the DNA chain using the position vector as a fundamental tool to describe its curvature and radius of curvature. I also show the native maple syntax for the graphics. You can download the maple center app to show different DNA trajectories based on the position vector. Developed for students of health sciences.
     

    k_adn.zip  (In spanish)

    https://www.maplesoft.com/applications/download.aspx?SF=154486/Plot_of_curvature_and_radius_of_curvature.mw

    Lenin Araujo Castillo

    Ambassador of Maple

    The numeric solution of ODE BVPs related to nanofluids is one of the most-common sources of Questions on MaplePrimes; perhaps the most-common source, with about 3 or 4 Questions per week over the last several years. The papers in this field are often shoddy, and they often use ad hoc methods for numeric solution of the BVPs. These methods usually have no error control. I have not seen any that come close to Maple's ability with BVPs. I have not analyzed any papers in this field that did not have either significant computational errors or significant omissions that make reproducing the entirety of the numeric computations impossible.

    These systems often have many parameters, both as input and output. Maple's dsolve(..., numeric) allows symbolic input parameters for IVPs but not BVPs. On the other hand, it allows symbolic output parameters for BVPs but not IVPs. By using the technique that I show in the attached worksheet, these distinctions in the way that parameters are handled can be made mostly transparent to the end user so that all parameters can be treated as symbolic. Once this has been done, it is easy to make plots (both 2-D and 3-D) whose independent variables are the input parameters themselves, and whose dependent variables are the output parameters.

    Other techniques covered in this worksheet are

    • how to make a 3D surface plot combined with a dropped-shadow view of the associated contour plot;
    • how to make 3D plots with boxed axes but with the three annoying foreground lines removed;
    • how to do a statisical fit to express an output parameter as a function of the input parameters using only data that's been collected during the production of the plots.


    Numeric solution of ODE BVPs with many parameters


    Author of this Maple worksheet: Carl Love <mailto:carl.j.love@gmail.com>, 14-Oct-2018


    This worksheet is a critique of and an attempt to reproduce all numeric computations in the paper:


    M. Sheikholeslami, D.D. Ganji, M.M. Rashidi, "Magnetic field effect on unsteady flow and heat transfer using Buongiorno model", Journal of Magnetism and Magnetic Materials, 416 (2016) 164-173, Elsevier, 11-May-2016, http://dx.doi.org/10.1016/j.jmmm.2016.05.026


    That paper's authors' affiliations and email addresses:

    M. Sheikholeslami: Department of Mechanical Engineering, Babol Univeristy of Technology, Babol, Islamic Republic of Iran <mohsen.sheikholeslami@yahoo.com>, <m.sheikholeslmai@stu.nit.ac.ir>,

    D.D. Ganji: Department of Mechanical Engineering, Babol Univeristy of Technology, Babol, Islamic Republic of Iran <mirgang@nit.ac.ir>,

    M.M. Rashidi: Shanghai Key Lab of Vehicle Aerodynamics and Vehicle Thermal Management Systems, Tongji Univeristy, 4800 Cao An Road, Shanghai 201804, China (no email address given).


    All references to Equation numbers, Figure numbers, and Table numbers in this worksheet are from that paper.


    > 

    restart:

    > 

    Digits:= trunc(evalhf(Digits)); #generally a very efficient setting

    15

    Setup of BVP system:

    > 

    #ordinary differential equations:
    ODEs:= [
       #Eq 8:
       diff(f(eta),eta$4)
       - S*(diff(f(eta),eta$3)*(eta-f(eta)) + diff(f(eta),eta$2)*(3+diff(f(eta),eta)))
       - Ha^2*diff(f(eta),eta$2),

       #Eq 9:
       (1+4/3*Rd)*diff(theta(eta),eta$2)
       + Pr*(S*diff(theta(eta),eta)*(f(eta)-eta) + Ec*diff(f(eta),eta$2)^2)
       + Nb*diff(phi(eta),eta)*diff(theta(eta),eta) + Nt*diff(theta(eta),eta)^2,

       #Eq 10:
       diff(phi(eta),eta$2) + S*Sc*diff(phi(eta),eta)*(f(eta)-eta)
       + Nt/Nb*diff(theta(eta),eta$2)

       #All these ODEs are implicitly equated to 0.
    ]:

    <ODEs[]>; #Display the ODEs.
       

    Vector(3, {(1) = diff(diff(diff(diff(f(eta), eta), eta), eta), eta)-S*((diff(diff(diff(f(eta), eta), eta), eta))*(eta-f(eta))+(diff(diff(f(eta), eta), eta))*(3+diff(f(eta), eta)))-Ha^2*(diff(diff(f(eta), eta), eta)), (2) = (1+(4/3)*Rd)*(diff(diff(theta(eta), eta), eta))+Pr*(S*(diff(theta(eta), eta))*(f(eta)-eta)+Ec*(diff(diff(f(eta), eta), eta))^2)+Nb*(diff(phi(eta), eta))*(diff(theta(eta), eta))+Nt*(diff(theta(eta), eta))^2, (3) = diff(diff(phi(eta), eta), eta)+S*Sc*(diff(phi(eta), eta))*(f(eta)-eta)+Nt*(diff(diff(theta(eta), eta), eta))/Nb})

    > 

    #lower and upper boundary values of the independent variable:
    (LB,UB):= (0,1): #Eq 11

    #boundary conditions:
    BCs:= [
       #Eq 11:
       ([f, (D@@2)(f), D(theta), D(phi)](LB) =~ [0, 0, 0, 0])[],
       ([f, D(f), theta, phi](UB) =~ [1, 0, 1, 1])[]
    ];

    [f(0) = 0, ((D@@2)(f))(0) = 0, (D(theta))(0) = 0, (D(phi))(0) = 0, f(1) = 1, (D(f))(1) = 0, theta(1) = 1, phi(1) = 1]

    > 

    #parameters (input values to BVP system) and their default values:
    Params:= Record(
       #Eq 12:
       S=  0.5,  #Squeeze number
       Pr= 10.,  #Prandtl number
       Ec= 0.1,  #Eckert number
       Sc= 0.5,  #Schmidt number
       Ha= 2.,   #Hartman number
       Nb= 0.15, #Brownian motion parameter
       Nt= 0.15, #thermophoretic parameter
       Rd= 4.5   #radiation parameter
    ):
       

    > 

    #Named special computed boundary values (output values of the system): Note that each adds
    #exactly one parameter and one boundary condition to the system.

    NBVs:= [   
       -(D@@2)(f)(1) = `C*__f`,  #Eq 13: Skin friction coefficient
       -D(theta)(1) = `Nu*`      #Eq 14: Nusselt number
    ]:

    #just rewriting the above names in a more-convenient form:
    Nu:= `Nu*`:
    Cf:= `C*__f`:

    > 

    #Appliable module that calls dsolve for each
    #particular configuration of parameter values. (Maple's numeric BVPs require a separate
    #dsolve invocation for each specific set of parameter values (unlike IVPs, which can be
    #parameterized into a single dsolve invocation).)
    #
    #For every dsolve call through this module, the NBVs are evaluated and saved.

    Solve:= module()
    local
       nbvs_rhs:= rhs~(:-NBVs), #just the names
       Sol, #numeric dsolve BVP solution of any 'output' form
       ModuleApply:= subs(
          _Sys= {:-ODEs[], :-BCs[], :-NBVs[]},
          proc({
             #These are just default parameter values: They can be changed when the
             #procedure is called.
             S::realcons:=  Params:-S,
             Pr::realcons:= Params:-Pr,
             Ec::realcons:= Params:-Ec,
             Sc::realcons:= Params:-Sc,
             Ha::realcons:= Params:-Ha,
             Nb::realcons:= Params:-Nb,
             Nt::realcons:= Params:-Nt,
             Rd::realcons:= Params:-Rd
             #By extracting the default values from record Params, it is possible to change
             #them by changing the record.
          })
             Sol:= dsolve(_Sys, _rest, numeric);
             AccumData(Sol, {_options});
             Sol
          end proc
       ),
       AccumData:= proc(
          Sol::{Matrix, procedure, list({name, function}= procedure)},
          params::set(name= realcons)
       )
       local n, nbvs;
          if Sol::Matrix then
             nbvs:= seq(n = Sol[2,1][1,Pos(n)], n= nbvs_rhs)
          else
             nbvs:= (nbvs_rhs =~ eval(nbvs_rhs, Sol(:-LB)))[]
          fi;
          SavedData[params]:= Record[packed](params[], nbvs)
       end proc,
       ModuleLoad:= eval(Init)
    ;
    export
       SavedData, #table of Records
       Pos, #Matrix column indices of nbvs
       Init:= proc()
          Pos:= proc(n::name) option remember; local p; member(n, Sol[1,1], 'p'); p end proc;
          SavedData:= table();
          return
       end proc   
    ;
       ModuleLoad()
    end module:
     

    Now we attempt to recreate all the numeric computations of the paper.


    Figure 1 is conceptual, not computational, so there's no point in trying to reproduce it here.


    I can't attempt to reproduce Table 1 or Figure 2 because the paper doesn't specify the values of all the parameters used for those.


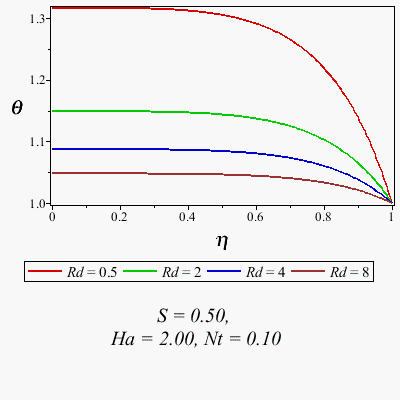
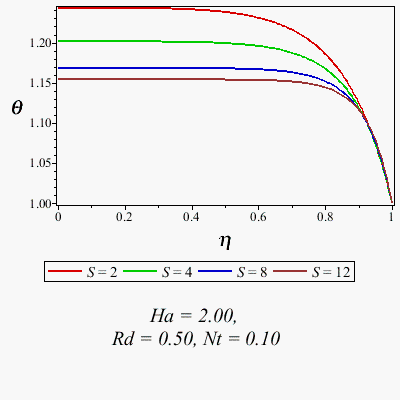
    Recreate Figure 3:

    > 

    colseq:= [red, green, blue, brown]:

    > 

    #parameter values that remain fixed for the entire set of plots:
    Pc:= Sc= 0.5, Nb= 0.1, Ec= 0.1, Pr= 10:
     

    > 

    #parameter values that remain fixed with each of the four plots::
    Ps:= [
       [S= 0.5, Ha= 2, Nt= 0.1],
       [Ha= 2, Rd= 0.5, Nt= 0.1],
       [S= 0.5, Rd= 0.5, Nt= 0.1],
       [S= 0.5, Ha= 2, Rd= 0.5]
    ]:

    #parameter value for each curve
    Pv:= [
       Rd= [0.5, 2, 4, 8],
       S=  [2, 4, 8, 12],
       Ha= [2, 4, 8, 12],
       Nt= [0.01, 0.05, 0.1, 0.2]
    ]:
          

    > 

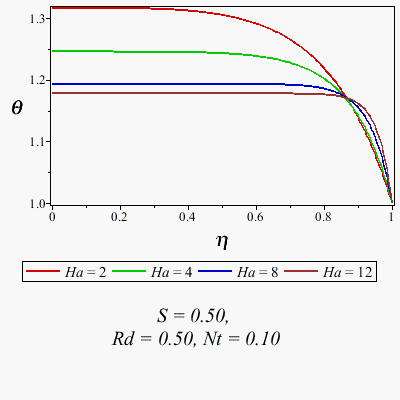
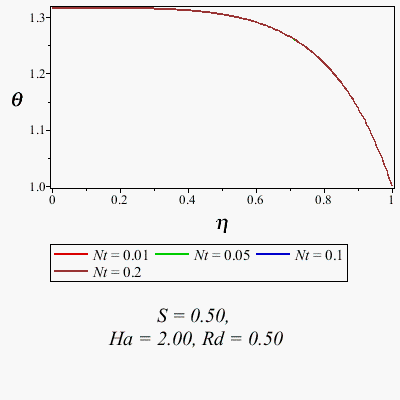
    for i to nops(Ps) do
       plots:-display(
          [seq(
             plots:-odeplot(
                Solve(lhs(Pv[i])= rhs(Pv[i])[j], Ps[i][], Pc),
                [eta, theta(eta)], 'color'= colseq[j], 'legend'= [lhs(Pv[i])= rhs(Pv[i])[j]]
             ),
             j= 1..nops(rhs(Pv[i]))
          )],
          'axes'= 'boxed', 'gridlines'= false,
          'labelfont'= ['TIMES', 'BOLDOBLIQUE', 16],
          'caption'= nprintf(
             cat("\n%a = %4.2f, "$nops(Ps[i])-1, "%a = %4.2f\n\n"), (lhs,rhs)~(Ps[i])[]
          ),
          'captionfont'= ['TIMES', 16]
       )
    od;

    The 4 plots agree with those in Fig. 3 in  the paper.


    Recreate Fig. 4.


    > 

    #procedure that generates a 2-D plot of an expression versus a varied parameter:
    ParamPlot2d:= proc(
       Y::{procedure, `module`}, #procedure that extracts y-value from Solve's dsolve solution
       X::name= range(realcons), #x-axis-parameter range
       FP::list(name= realcons), #fixed values of other parameters
       {
          eta::realcons:= :-LB, #independent variable value
          dsolveopts::list({name, name= anything}):= []  
       }
    )
       plot(
          x-> Y(
             Solve(
                lhs(X)= x, FP[],
                #Default dsolve options can be changed by setting 'dsolveopts':
                'abserr'= 0.5e-7, 'interpolant'= false, 'output'= Array([eta]), dsolveopts[]
             )
          ),
          rhs(X),
          #Default plot options can be changed by putting the option in the ParamPlot2d call:
          'numpoints'= 25, 'axes'= 'boxed', 'gridlines'= false,
          'labelfont'= ['TIMES', 'BOLDOBLIQUE', 16],
          'caption'= nprintf(cat("%a = %4.2f, "$nops(FP)-1, "%a = %4.2f"), (lhs,rhs)~(FP)[]),
          'captionfont'= ['TIMES', 16],
          _rest
       )
    end proc:

    > 

    #procedure that extracts Nusselt number from dsolve solution:
    GetNu:= (Sol::Matrix)-> Sol[2,1][1, Solve:-Pos(:-Nu)]:

    > 

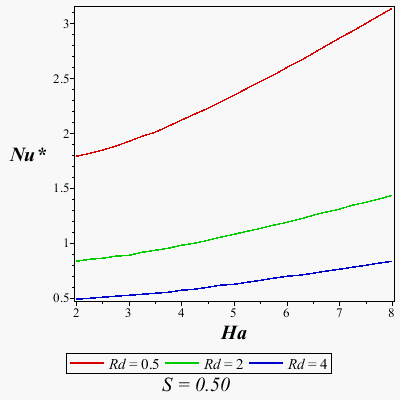
    RD:= [0.5, 2, 4]:
    plots:-display(
       [seq(
          ParamPlot2d(
             GetNu, Ha= 2..8, [S= 0.5],
             dsolveopts= [Rd= RD[k], Sc= 0.5, Nb= 0.1, Ec= 0.1, Nt= 0.1, Pr= 10],
             'legend'= [Rd= RD[k]], 'color'= colseq[k], 'labels'= [Ha, Nu]
          ),
          k= 1..nops(RD)
       )]
    );

    > 

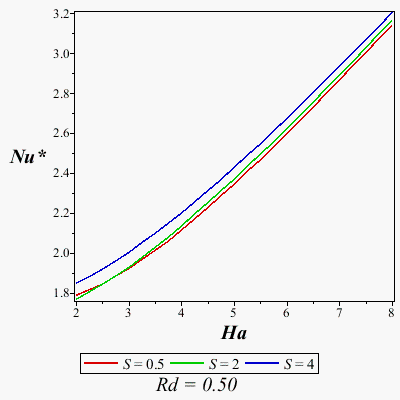
    SV:= [0.5, 2, 4]:
    plots:-display(
       [seq(
          ParamPlot2d(
             GetNu, Ha= 2..8, [Rd= 0.5],
             dsolveopts= [S= SV[k], Sc= 0.5, Nb= 0.1, Ec= 0.1, Nt= 0.1, Pr= 10],
             'legend'= [S= SV[k]], 'color'= colseq[k], 'labels'= [Ha, Nu]
          ),
          k= 1..nops(SV)
       )]
    )

    The above two plots match those of Fig. 4 in the paper.


    > 

    #procedure that generates 3-D plots (dropped-shadow contour + surface) of an expression
    #versus two varied parameters:

    ParamPlot3d:= proc(
       Z::{procedure, `module`}, #procedure that extracts z-value from Solve's dsolve solution
       X::name= range(realcons), #x-axis-parameter range
       Y::name= range(realcons), #y-axis-parameter range
       FP::list(name= realcons), #fixed values of other parameters
       {
          #fraction of empty space above and below plot (larger "below"
          #value improves view of dropped-shadow contourplot):
          zmargin::[realcons,realcons]:= [.05,0.15],
          eta::realcons:= :-LB, #independent variable value
          dsolveopts::list({name, name= anything}):= [],
          contouropts::list({name, name= anything}):= [],
          surfaceopts::list({name, name= anything}):=[]    
       }
    )
    local
       LX:= lhs(X), RX:= rhs(X), LY:= lhs(Y), RY:= rhs(Y),
       Zremember:= proc(x,y)
       option remember; #Used because 'grid' should be the same for both plots.
          Z(
             Solve(
                LX= x, LY= y, FP[],
                #Default dsolve options can be changed by setting 'dsolveopts':
                'abserr'= 0.5e-7, 'interpolant'= false, 'output'= Array([eta]),  
                dsolveopts[]
             )
          )
       end proc,
       plotspec:= (Zremember, RX, RY),
       C:= plots:-contourplot(
          plotspec,
          #These default plot options can be changed by setting 'contouropts':
          'grid'= [25,25], 'contours'= 5, 'filled',
          'coloring'= ['yellow', 'orange'], 'color'= 'green',
          contouropts[]
       ),
       P:= plot3d(
          plotspec,
          #These default plot options can be changed by setting 'surfaceopts':
          'grid'= [25,25], 'style'= 'surfacecontour', 'contours'= 6,
          surfaceopts[]
       ),
       U, L #z-axis endpoints after margin adjustment
    ;
       #Stretch z-axis to include margins:
       (U,L):= ((Um,Lm,M,m)-> (M*(Lm-1)+m*Um, M*Lm+m*(Um-1)) /~ (Um+Lm-1))(
          zmargin[],
          (max,min)(op(3, indets(P, 'specfunc'('GRID'))[])) #actual z-axis range
       );
       plots:-display(  #final plot to display/return
          [
             plots:-spacecurve(
                {
                   [[lhs(RX),rhs(RY),U],[rhs(RX),rhs(RY),U],[rhs(RX),rhs(RY),L]], #yz backwall
                   [[rhs(RX),rhs(RY),U],[rhs(RX),lhs(RY),U],[rhs(RX),lhs(RY),L]]  #xz backwall
                },
                'color'= 'grey', 'thickness'= 0
             ),
             plottools:-transform((x,y)-> [x,y,L])(C), #dropped-shadow contours
             P
          ],
          #These default plot options can be changed simply by putting the option in the
          #ParamPlot3d call:
          'view'= ['DEFAULT', 'DEFAULT', L..U], 'orientation'= [-135, 75], 'axes'= 'frame',
          'labels'= [lhs(X), lhs(Y), Z], 'labelfont'= ['TIMES', 'BOLDOBLIQUE', 16],
          'caption'= nprintf(cat("%a = %4.2f, "$nops(FP)-1, "%a = %4.2f"), (lhs,rhs)~(FP)[]),
          'captionfont'= ['TIMES', 14],
          'projection'= 2/3,   
          _rest
       )
    end proc:

    Reproduce the twelve 3-D plots of Figure 5. Note that every plot uses a default grid of 25x25, so requires 625 complete solutions of the BVP. So, this might be slower than you expect.

    > 

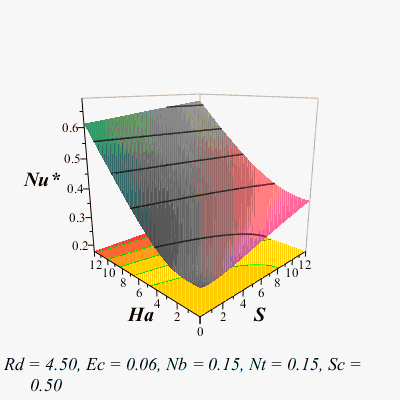
    ParamPlot3d(
       GetNu, S= 0..12, Ha= 0..12, [Rd= 4.5, Ec= 0.06, Nb= 0.15, Nt= 0.15, Sc= 0.5],
       labels= [S, Ha, Nu]
    );

    The above plot matches the paper.


    > 

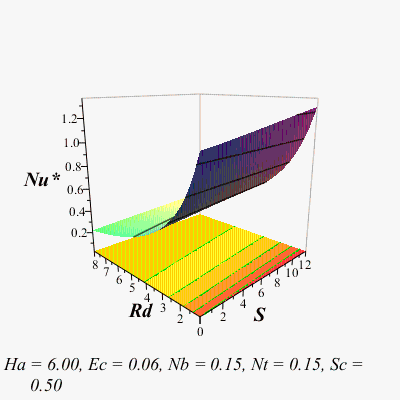
    ParamPlot3d(
       GetNu, S= 0..12, Rd= 1..8, [Ha= 6, Ec= 0.06, Nb= 0.15, Nt= 0.15, Sc= 0.5],
       labels= [S, Rd, Nu]
    );

    The above plot matches the paper.


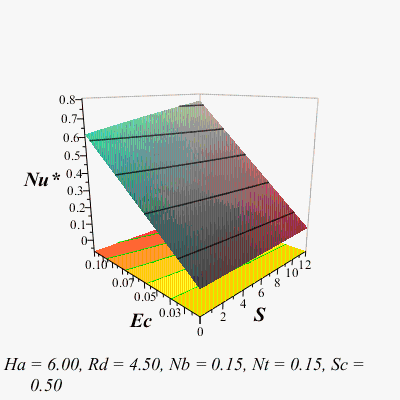
    > 

    ParamPlot3d(
       GetNu, S= 0..12, Ec= 0.01..0.10, [Ha= 6, Rd= 4.5, Nb= 0.15, Nt= 0.15, Sc= 0.5],
       labels= [S, Ec, Nu]
    );

    The above plot matches the paper.


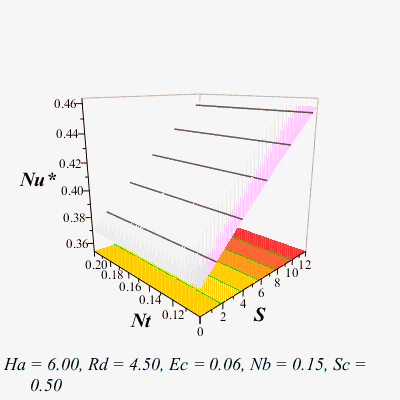
    > 

    ParamPlot3d(
       GetNu, S= 0..12, Nt= 0.1..0.2, [Ha= 6, Rd= 4.5, Ec= 0.06, Nb= 0.15, Sc= 0.5],
       labels= [S, Nt, Nu]
    );

    The above plot doesn't match the corresponding one in the paper!


    > 

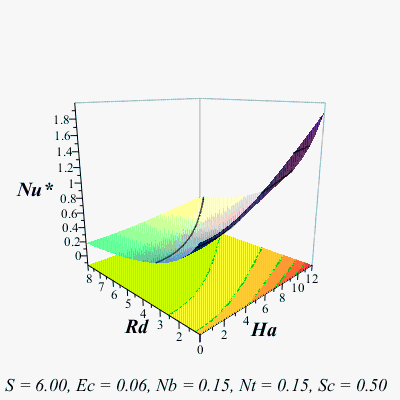
    ParamPlot3d(
       GetNu, Ha= 0..12, Rd= 1.0..8.0, [S= 6, Ec= 0.06, Nb= 0.15, Nt= 0.15, Sc= 0.5],
       labels= [Ha, Rd, Nu]
    );

    The above plot matches the paper.


    > 

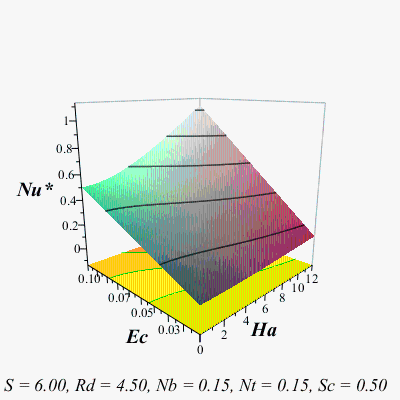
    ParamPlot3d(
       GetNu, Ha= 0..12, Ec= 0.01..0.1, [S= 6, Rd= 4.5, Nb= 0.15, Nt= 0.15, Sc= 0.5],
       labels= [Ha, Ec, Nu]
    );
       

    The above plot matches the paper.


    > 

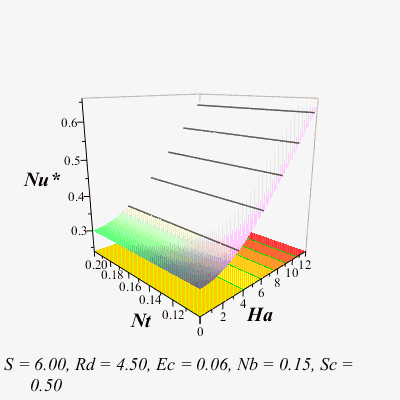
    ParamPlot3d(
       GetNu, Ha= 0..12, Nt= 0.1..0.2, [S= 6, Rd= 4.5, Ec= 0.06, Nb= 0.15, Sc= 0.5],
       labels= [Ha, Nt, Nu]
    );

    The above plot matches the paper.


    > 

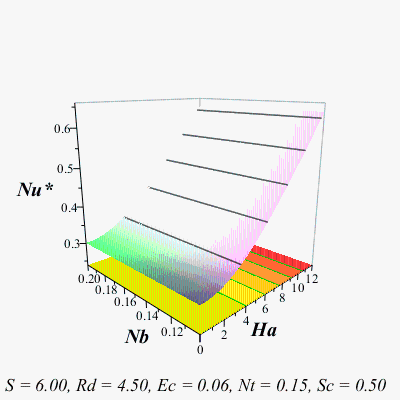
    ParamPlot3d(
       GetNu, Ha= 0..12, Nb= 0.1..0.2, [S= 6, Rd= 4.5, Ec= 0.06, Nt= 0.15, Sc= 0.5],
       labels= [Ha, Nb, Nu]
    );

    The above plot matches the paper.


    > 

    ParamPlot3d(
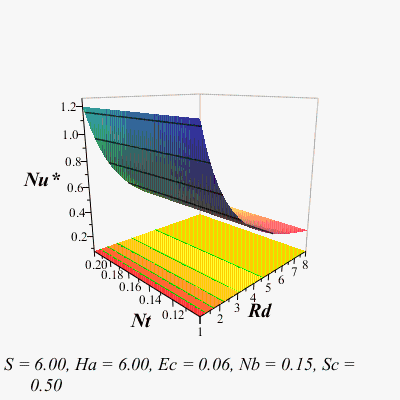
       GetNu, Rd= 1.0..8.0, Nt= 0.1..0.2, [S= 6, Ha= 6, Ec= 0.06, Nb= 0.15, Sc= 0.5],
       labels= [Rd, Nt, Nu]
    );

    The above plot matches the paper.


    > 

    ParamPlot3d(
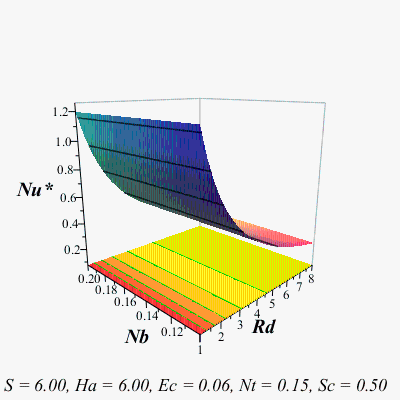
       GetNu, Rd= 1.0..8., Nb= 0.1..0.2, [S= 6, Ha= 6, Ec= 0.06, Nt= 0.15, Sc= 0.5],
       labels= [Rd, Nb, Nu]
    );

    The above plot matches the paper.


    > 

    ParamPlot3d(
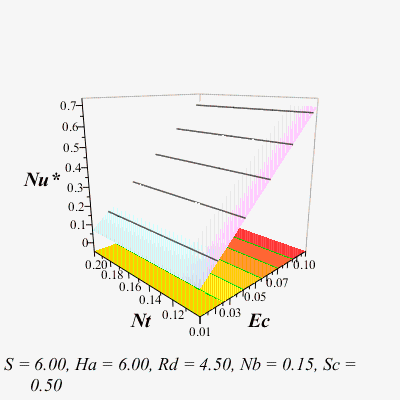
       GetNu, Ec= 0.01..0.1, Nt= 0.1..0.2, [S= 6, Ha= 6, Rd= 4.5, Nb= 0.15, Sc= 0.5],
       labels= [Ec, Nt, Nu]
    );

    > 

    ParamPlot3d(
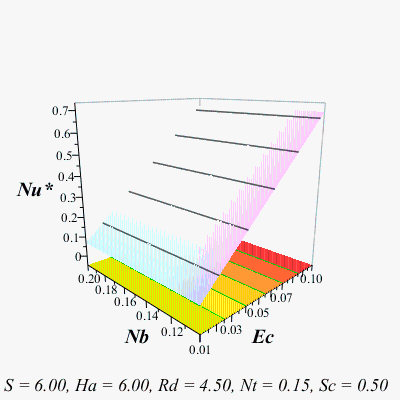
       GetNu, Ec= 0.01..0.1, Nb= 0.1..0.2, [S= 6, Ha= 6, Rd= 4.5, Nt= 0.15, Sc= 0.5],
       labels= [Ec, Nb, Nu]
    );

    The above plot does not match the corresponding one in the paper!


    Recreate Fig. 6:

    > 

    #parameter values that remain fixed for the entire set of plots:
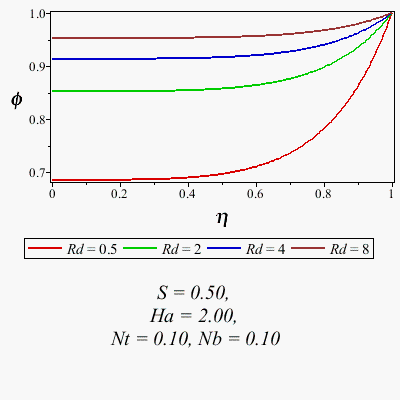
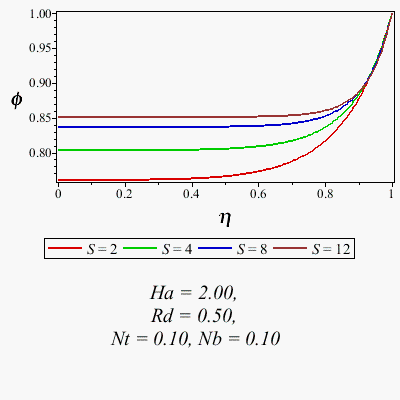
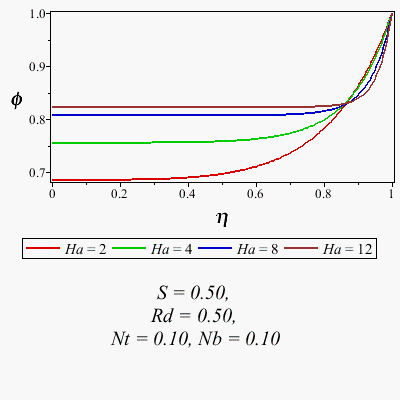
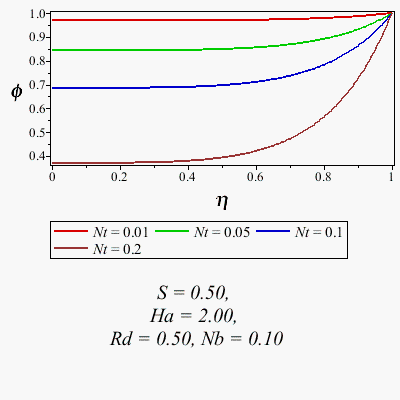
    Pc:= Sc= 0.5, Ec= 0.1, Pr= 10:
     

    > 

    #parameter values that remain fixed within each plot:
    Ps:= [
       [S= 0.5, Ha= 2, Nt= 0.1, Nb= 0.1],
       [Ha= 2, Rd= 0.5, Nt= 0.1, Nb= 0.1],
       [S= 0.5, Rd= 0.5, Nt= 0.1, Nb= 0.1],
       [S= 0.5, Ha= 2, Rd= 0.5, Nb= 0.1],
       [S= 0.5, Ha= 2, Rd= 0.5, Nt= 0.1]
    ]:

    #parameter value for each curve in each plot
    Pv:= [
       Rd = [0.5, 2, 4, 8],
       S= [2, 4, 8, 12],
       Ha= [2, 4, 8, 12],
       Nt= [0.01, 0.05, 0.1, 0.2],
       Nb= [0.1, 0.2, 0.4, 0.6]
    ]:
          

    > 

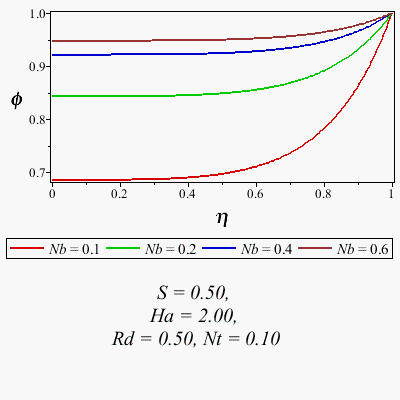
    for i to nops(Ps) do
       plots:-display(
          [seq(
             plots:-odeplot(
                Solve(lhs(Pv[i])= rhs(Pv[i])[j], Ps[i][], Pc),
                [eta, phi(eta)], 'color'= colseq[j], 'legend'= [lhs(Pv[i])= rhs(Pv[i])[j]]
             ),
             j= 1..nops(rhs(Pv[i]))
          )],
          'axes'= 'boxed', 'gridlines'= false,
          'labelfont'= ['TIMES', 'BOLDOBLIQUE', 16],
          'caption'= nprintf(
             cat("\n%a = %4.2f, "$nops(Ps[i])-1, "%a = %4.2f\n\n"), (lhs,rhs)~(Ps[i])[]
           ),
           'captionfont'= ['TIMES', 16]
       )
    od;

    The five plots above match Fig. 6 from the paper.


    Generate Eq. 31: At this point, we have a huge database of Nusselt numbers (15,186 records to be exact) computed at various parameter values.

    > 

    NusseltList:= [entries(Solve:-SavedData, nolist)]:

    > 

    nops(NusseltList);

    15136

    Sheikholeslami, et al, call these the "active parameters" (because they're the ones that have varied in the above computations):

    > 

    V:= [S, Ha, Rd, Ec, Nt, Nb]:

    > 

    NusseltData:= Matrix(map(R-> [map(v-> R[v], V)[], R[Nu]], NusseltList));